Introduction
Factory engineers supervise working automatons with the same care programmers give to critical cloud software. Developers inspect computer systems daily, repair code defects, and publish fresh software revisions. Moving floor machines require identical hands-on supervision throughout their operational lifetime. Sturdy machines transport heavy steel crates, fuse automotive panels, and sanitize slick hospital hallways. Over time, internal gears degrade, battery reserves sink, and optical navigation sensors gather grime. Unchecked software patches can also spark sudden workplace mishaps. For these reasons, maintenance crews evaluate physical parts, observe real-time health data, and push fast digital fixes across local networks. Dedicated specialists supervise the full mechanized squad across every working shift. Routine maintenance ensures that every mobile unit remains secure, swift, and dependable. Students and new developers can master these essential methods without confusion. Anyone seeking clear guides can explore RobotsOps.com to study modern machine supervision. The educational hub offers straightforward lessons covering digital sandbox trials, multi-unit tracking, and modern industrial tooling. Readers discover realistic techniques to direct fleets with absolute assurance.
What Is RobotOps?
Workplace teams rely on RobotOps to supervise moving equipment across active commercial sites. Initially, designers assemble a physical frame and program its onboard guidance system. Afterward, workers transport the finished machine directly into an operating facility. The true responsibility starts once the machine begins its daily runs. Support technicians track the unit as it navigates aisles and doorways. They inspect electric drive wheels, front-facing cameras, and joint motors. They beam updated software revisions across local radio bands. They also replace slipping drive belts before serious workplace breakdowns occur. If an autonomous cart suddenly freezes, technicians analyze the issue immediately. Industry experts call this rapid troubleshooting incident management. This operational domain differs substantially from standard enterprise computing. Standard software services live inside quiet corporate server farms. Industrial units possess physical steel frames that roll over ramps, pivot past people, and transport heavy cargo. Faulty software instructions could crush an expensive crate or bend a steel joint. As a result, operational oversight shields both the mechanical hardware and the surrounding human staff.
Why RobotOps Matters
Directing a single automated vehicle feels simple and stress-free. That lone unit glides along an open concrete corridor and finishes its assigned task. Managing twenty, sixty, or two hundred autonomous transporters introduces complicated logistical hurdles. Fleets share tight hallways and crowded loading docks. Individual carts deplete their electrical reserves right during critical rush periods. Other vehicles lose radio reception behind tall steel racks. Dust coats front lenses, leaving navigation algorithms completely blind. A problematic code release might freeze dozens of rovers simultaneously. When multiple transport units block a narrow depot aisle, entire facility operations halt. Floor workers cannot reach storage racks, and delivery trucks depart empty. These idle delays drain money and reduce daily output. A structured operations program eliminates these disastrous bottlenecks. It presents every operating vehicle on a unified visual display. Supervisors catch tiny warning indicators early and solve them before severe damage spreads. Thanks to this routine vigilance, the plant remains productive and safe throughout every shift.
RobotOps Areas
The table below outlines the core functional pillars of modern machine management.
| RobotOps Area | Simple Meaning | Main Goal |
| Digital Trials | Running code inside pretend test environments | Discover glitches before physical metal moves |
| Live Telemetry | Inspecting vehicle speed and component heat | Identify failing hardware parts right away |
| Wireless Updates | Delivering fresh programs across the air | Add helpful capabilities without physical cables |
| Incident Care | Assisting halted units on the floor | Return frozen equipment back to duty |
| Path Coordination | Assigning daily tasks across many units | Prevent rolling bottlenecks along narrow corridors |
Robot Fleet Management Made Simple
Centralized fleet supervision allows technicians to guide dozens of machines from an operational control screen. A fleet represents a collective group of automated units pursuing common goals. A floor manager inspects an interactive web dashboard to monitor the complete mobile team. The digital map reveals the live coordinates of every roaming unit. It details remaining battery charge, ground velocity, and active dispatch orders. The routing system transfers new errands to whichever machine stands nearest to the freight. If an internal sensor detects mechanical trouble, the unit beams an alert to the oversight team. The specialist can halt the transporter or direct its movement with an electronic controller. The platform also confirms the current software release on every unit. This organized supervision keeps the entire team running smoothly.
The table below compares basic single-unit support against comprehensive fleet management.
| Feature | Single Robot Care | Robot Fleet Management |
| Interface Scope | Displays a single cart on screen | Displays hundreds of rovers at once |
| Work Dispatch | Operators assign chores one by one | Logic routes orders to ideal carts |
| Failure Warnings | Buzzers ring on the physical frame | Alerts reach the whole operations team |
| Code Upgrades | Technicians attach physical cables | Networks broadcast code updates everywhere |
Industrial Robotics and Robotics Automation
Manufacturing plants depend on industrial robotics to drive heavy articulated arms through demanding shifts. These multi-jointed steel arms weld metal truck frames, package food cartons, and place delicate electronic chips. They depend on optical scanners for positional awareness and dedicated computer controllers for precise execution. The controller functions as the primary computer brain for the robotic limb. Production lines require these arms to repeat swift motions without missing a beat. Heavy continuous motion still stresses mechanical joints after hundreds of shifts. Gear assemblies heat up, and internal electrical wiring stretches over time. Robotics automation links these heavy lifting arms directly to automated conveyors and packing machinery. Modern operational workflows allow plant specialists to supervise these high-powered limbs every minute. Technicians monitor thermal readouts, power consumption, and mechanical cycle rates. When an actuator overheats, the software notifies the maintenance crew. Technicians replace worn bearings during scheduled lunch breaks, keeping production lines running without costly stops.
Real-World Robot Examples
Different facilities deploy customized machines to accomplish demanding manual labor. The table below lists common automation platforms alongside their operational requirements.
| Robot Type | Common Work | RobotOps Need |
| Heavy Factory Limb | Welds steel frames on truck beds | Joint heat checks and torque balance tests |
| Low Warehouse Rover | Transports loaded pallets between shelves | Route planning and battery dock supervision |
| Medical Courier Bot | Carries laboratory samples to nurses | Door sensor audits and elevator sync checks |
| Outdoor Farm Rover | Scouts field crops and harvests berries | Mud clearance and long-range radio tests |
Robotics Software and ROS 2
Robotics software comprises the digital programs that guide mechanical movements and sensory processing. Many engineers choose ROS 2, which stands for Robot Operating System 2. ROS 2 does not substitute for standard computer operating platforms like Linux. It serves as an adaptable software framework that lets independent machine components share information seamlessly. Inside ROS 2, specialized functional programs operate as nodes. One node captures images from an optical camera. Another node supplies power signals to an electric drive motor. Nodes publish their status using dedicated communication lines called topics. When a machine undertakes a multistep route, it initiates actions. Actions instruct the vehicle to cross a warehouse while transmitting regular progress updates. Operations teams utilize ROS 2 to gather performance diagnostics from every running node. They identify whether a node stutters or consumes excessive processing memory. Consequently, onboard machine software remains stable and straightforward to control.
Robot Simulation Before Real Deployment
Specialists rely on digital simulation to observe a machine inside a virtual environment before building physical hardware. Software engineers assemble a digital twin of both the robotic cart and the surrounding facility floor. A digital twin acts as a digital copy that imitates physical real-world traits. Inside this virtual domain, developers evaluate how the digital model navigates, speeds up, and stops. They test spatial pathfinding code and proximity sensors without risking hardware damage. They inject digital obstacles straight into the rover’s path to evaluate emergency braking routines. If the simulated model strikes a digital barrier, no hardware sustains damage and no people face danger. Engineers can run hundreds of virtual navigation challenges in just a few minutes. Virtual trials cannot entirely replace real-world floor evaluations, however. Facility floors present oil residues, uneven flooring, and strange shadows that virtual physics engines overlook. Therefore, engineers confirm code stability in virtual sandboxes first, followed by careful physical tests on the floor.
Autonomous Mobile Robots
Autonomous Mobile Robots, commonly called AMRs, traverse industrial buildings under their own navigational logic. Unlike earlier transport carts, AMRs do not depend on magnetic tape or wires taped across floors. AMRs employ laser radar sensors, visual cameras, and digital space maps to choose their own travel routes. Picture a bustling distribution hub packed with sorting workers, storage bins, and rolling dollies. An AMR carries a wooden pallet loaded with merchandise toward a loading ramp. When a human walks across the travel corridor, the AMR stops smoothly. It maps a fresh path around the person and continues its delivery. AMRs also supervise their own internal power levels, heading toward charging docks before depleting their energy. Operations platforms permit facility supervisors to track every mobile transporter across the facility. The central software disperses transport routes so carts avoid choking vital facility intersections.
Robotics Operations Center
Firms construct a Robotics Operations Center, or ROC, as a centralized monitoring facility for distributed automated systems. The space looks like a satellite tracking room packed with wide video arrays on the walls. Specialists observe incoming data streams arriving from automated units running across nationwide facilities. Technicians refer to this continuous stream of performance data as telemetry. Telemetry covers battery levels, motor temperatures, driving speeds, and wireless signal strength. If a machine stalls inside a distant storage facility, the ROC console flashes an alert. The operator checks the vehicle’s forward camera stream on their workstation monitor. They guide the stalled rover past the blocking crate using a connected joystick. The engineering group also analyzes software faults, performance lags, and broad efficiency patterns across the fleet. As organizations expand their robotic numbers, an ROC proves essential for keeping operations reliable and orderly.
Real-Life Scenarios
- An automated cleaning rover drops off the wireless network in a basement corridor: The cart parks safely against a wall because it cannot verify pathing clearances. Control room monitors display an offline alert on their screen. They notify a facility custodian, who maneuvers the cart back into strong network reception.
- A warehouse transport unit discovers an overheated drive motor: The unit transmits a telemetry error code while carrying a pallet across a busy aisle. The fleet software transfers the moving job to an alternate unit nearby. The warm cart guides itself toward the repair workshop before the motor fails.
- A flawed code release causes twelve automated carts to pivot endlessly in circles: Support engineers observe the odd movement through active camera screens. A developer clicks the rollback function to reinstall the earlier stable code build within five minutes.
Common Mistakes to Avoid in Robot Operations
- Bypassing virtual test simulations: Teams load untested code directly onto physical units, leading to crushed equipment and bent arms.
- Overlooking battery cycles: Supervisors forget automatic charging thresholds, stranding dead rovers in busy production lanes.
- Pushing fleet-wide updates at once: Distributing unproven code across all machines at the same moment can halt the entire facility.
- Ignoring facility dead zones: Machines roam into shielded metal racks, lose radio contact, and stop moving completely.
- Neglecting camera cleaning: Crews let oily dust coat optical lenses, making vehicles spot phantom obstacles and freeze in place.
- Omitting remote driving tools: Operators forget to set up remote control software, forcing staff to push heavy units manually.
- Disregarding tiny sensor warnings: Techs ignore minor heat spikes until an expensive drive motor burns out entirely.
- Skipping floor staff training: Workers feel nervous around rolling carts because nobody explained how the safety lasers function.
How RobotsOps.com Helps Learners
Entering the robotics supervision field can seem overwhelming, yet approachable educational resources make the learning path simple. RobotsOps.com stands as a dedicated educational destination built for engineering students, coders, and technical leaders. The platform emphasizes actionable technical insights that assist professionals in their day-to-day work. Readers can read approachable guides detailing core RobotOps strategies and everyday robotics operations. The content unpacks extensive subjects like robot fleet management and autonomous mobile robots into bite-sized chapters. You can explore how industrial robotics systems drive speed across contemporary manufacturing plants. The site also covers essential robotics software, ROS 2 principles, and computer robot simulation environments. If you want to grasp how an active robotics operations center tracks machine status, this learning resource delivers clear explanations. The platform covers modern robotics automation ideas using plain English, skipping complicated technical buzzwords.
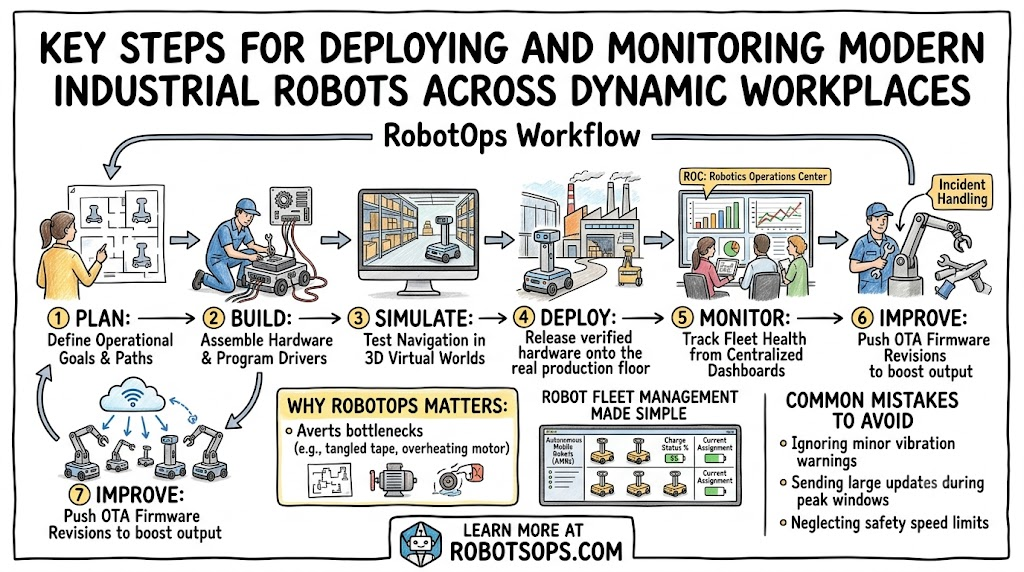
A Simple RobotOps Workflow
Field specialists supervise their automated machinery through a continuous development loop:
- Plan: The operational team establishes exact transport duties and safety limits for the machinery.
- Build: Software coders create guidance algorithms and engineers assemble physical frames.
- Test: Technicians inspect individual drive motors and navigation sensors on an assembly table.
- Simulate: The software group validates code functions inside a 3D digital sandbox.
- Deploy: Technicians beam the verified software build directly onto active machines.
- Monitor: System operators track battery depletion, motor heat, and vehicle speeds via central dashboards.
- Fix: Floor specialists resolve sensor alarms, software crashes, and blocked carts without delay.
- Improve: Developers examine shift data to refine subsequent software revisions.
This practical operational rhythm makes automated equipment more reliable throughout every working week.
Frequently Asked Questions
1. What does RobotOps mean in simple words?
Technical crews apply RobotOps to define the continuous oversight, health tracking, and maintenance of field machinery. It bridges software development practices with physical hardware upkeep on production floors. Just as smart devices need frequent software updates, rolling industrial machines require active daily care to operate reliably and safely near people.
2. How is RobotOps different from regular DevOps?
Traditional DevOps manages code services that operate inside remote web servers and digital clouds. RobotOps governs physical steel units that roll across concrete, rotate, and haul heavy crates. A basic bug in DevOps might slow down an online store. That same defect in RobotOps could steer an autonomous cart into a concrete wall.
3. What is an Autonomous Mobile Robot?
An AMR navigates commercial facilities on its own without relying on magnetic strips or guide wires stuck on floors. These smart vehicles rely on laser rangefinders and digital layouts to calculate secure travel routes. When a worker walks into its lane, the vehicle stops safely and plots an alternate route.
4. What is ROS 2 used for?
ROS 2 gives engineers an open software toolbox for designing dependable machine programs. It links central computing boards to electric motors, collision sensors, and guidance cameras. This shared architecture enables developers to construct sophisticated robot logic without writing custom device drivers from scratch.
5. Why do engineers simulate robots before buying them?
Engineers generate digital twin models to catch programming flaws before physical components suffer damage. Digital sandbox testing confirms whether machines can navigate hallways and stop near unexpected barriers. Validating software inside a computer saves funding, prevents hardware damage, and protects floor personnel during development trials.
6. What happens in a Robotics Operations Center?
A Robotics Operations Center functions like an air traffic control desk for fleets of automated machines. Human operators review wide displays that show battery reserves, physical positions, and equipment warnings. When a vehicle halts inside a distant facility, an operator inspects live camera angles and resolves the problem remotely.
7. Why do robots need over-the-air updates?
Over-the-air deployment allows support teams to distribute software patches across local wireless bands. Rather than attaching diagnostic cables to hundreds of individual vehicles, engineers upgrade the entire machine fleet simultaneously. This rapid update path saves dozens of manual work hours and protects hardware against software bugs.
8. What causes robots to get stuck in warehouses?
Vehicles typically halt because of dead wireless spots, dirty optical lenses, or loose debris scattered across aisles. When onboard sensors cannot confirm clear pathing, safety protocols force the vehicle to stop. Operations teams study these stoppage logs to fix building radio dead spots and schedule lens cleaning intervals.
9. What is robot telemetry data?
Telemetry represents the stream of operational statistics that machines transmit to central monitoring servers. This stream includes battery percentages, internal motor temperatures, travel velocity, and obstacle warnings. Supervisors study these values to replace worn bearings before parts fail in the middle of a shift.
10. Can small companies use RobotOps practices?
Small businesses operating two or three automated carts gain major advantages from these habits. Monitoring battery drain rates, storing clean software backups, and checking proximity sensors avoids costly hardware breakdowns. Structured operational routines help small businesses expand their automation fleets without unnecessary headaches.
11. Does RobotOps replace human workers?
RobotOps actually creates rewarding technical positions for people across various industries. Plants need technicians to monitor control panels, service mechanical joints, wipe sensors, and assist stalled vehicles. This transition moves workers away from heavy physical lifting into skilled maintenance and technical support careers.
12. Where can beginners learn about robotics operations?
Beginners can study instructional materials covering fleet software, system monitoring, and automated manufacturing workflows. Educational platforms such as RobotsOps.com supply clear tutorials and beginner articles. Learners can study ROS 2 workflows, digital simulation basics, and fleet oversight tools to build strong technical careers.
CONCLUSION
Directing automated facilities requires far more than assembling metal parts and loading basic operational code. Sustainable operational success requires disciplined RobotOps habits through every working shift. Engineering teams must unite robot fleet management, modern robotics software, and deep robot simulation practices. Supervisors must watch both industrial robotics arms on manufacturing lines and autonomous mobile robots traversing warehouse floors. Frameworks like ROS 2 and dedicated monitoring consoles enable technicians to resolve minor bugs before full production halts. As more industries embrace robotics automation, supervising mechanical hardware becomes an indispensable trade skill. Mastering these practical operational methods equips engineers and students for the evolving automation sector. Readers interested in expanding their technical knowledge can visit RobotsOps.com for practical educational guides.
